
Development of Robust Navigation and Automated Path Recovery System for Agricultural Robots Integrating GNSS and LiDAR: A Simulation Study
Article Sidebar
Main Article Content
Abstract
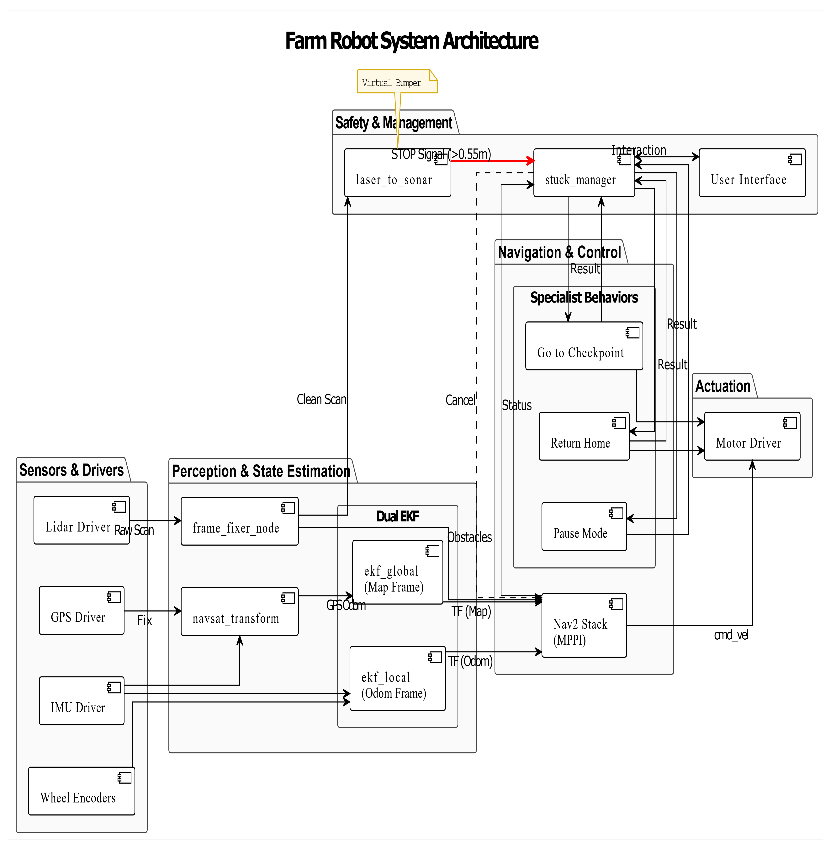
This research presents the development of a Robust Navigation System for agricultural robots operating in unstructured environments. The system integrates GNSS-based localization with local obstacle avoidance utilizing a Dynamic Local Costmap processed from LiDAR data. Additionally, a "Stagnation Manager" based on a Finite State Machine (FSM) was developed to monitor kinematic states against control commands and automatically trigger recovery behaviors upon detecting stagnation events. The proposed system was validated in a simulation environment using Gazebo on the ROS 2 Jazzy operating system, with the environment constructed using spatial structures referenced from aerial imagery of actual agricultural fields. The results demonstrate that the system can autonomously detect and resolve stuck conditions, significantly enhancing operational reliability and reducing the burden of continuous operator monitoring.
Article Details

This work is licensed under a Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License.
Articles in this journal are copyrighted by the x may be read and used for academic purposes, such as teaching, research, or citation, with proper credit given to the author and the journal.use or modification of the articles is prohibited without permission.
statements expressed in the articles are solely the opinions of the authors.
authors are fully responsible for the content and accuracy of their articles.
other reuse or republication requires permission from the journal."
References
ประดิษฐ์ หมู่เมืองสอง, สุชญาน หรรษสุข. 2550. การวิเคราะห์การสั่นสะเทือน. กรุงเทพมหานคร: ซีเอ็ดยูเคชั่น.
สยาม ตุ้มแสงทอง. 2546. การปรับปรุงเครื่องคัดขนาดผลมังคุดแบบจานหมุน. วิทยานิพนธ์วิศวกรรมศาสตร์มหาบัณฑิต. กรุงเทพมหานคร: บัณฑิตวิทยาลัย, มหาวิทยาลัยเกษตรศาสตร์.
Bechar and Vigneault 2016 Bechar, A., & Vigneault, C. (2016). Agricultural robots for field operations: Concepts and components. Biosystems Engineering, 149, 94–111. (เปเปอร์นี้คือตัวแม่บทเรื่องสภาพแวดล้อมไร้โครงสร้าง)
Duckett et al. 2018 Duckett, T., Pearson, S., Blackmore, S., & Grieve, B. (2018). Agricultural Robotics: The Future of Robotic Agriculture. UK-RAS Network White Papers. (เปเปอร์นี้ยืนยันเรื่องหุ่นยนต์ช่วยลดภาระและเพิ่มประสิทธิภาพ)
Office of Agricultural Economics 2023 Office of Agricultural Economics. (2023). Agricultural Statistics of Thailand 2022. Ministry of Agriculture and Cooperatives. (ข้อมูลสถิติยืนยันความสำคัญของเกษตรไทย)
Poapongsakorn and Pantakua 2017 Poapongsakorn, N., & Pantakua, P. (2017). Agriculture 4.0: Obstacles and how to break through. Thailand Development Research Institute (TDRI). (งานวิจัย TDRI เรื่องปัญหาแรงงานและต้นทุน)
Bengochea-Guevara, J.M., Conesa-Muñoz, J., Andújar, D., Ribeiro, A. 2016. Merge Fuzzy Visual Servoing and GPS-Based Planning to Obtain a Proper Navigation Behavior for a Small Crop-Inspection Robot. Sensors 16(2), 276.
Cui, L., Le, F., Xue, X., Sun, T., Jiao, Y. 2024. Design and Experiment of an Agricultural Field Management Robot and Its Navigation Control System. Agronomy 14(4), 654.
Fehér, Á., Domina, Á., Bárdos, Á., Aradi, S., Bécsi, T. 2025. Path planning via reinforcement learning with closed-loop motion control and field tests. Engineering Applications of Artificial Intelligence 142, 109870.
Guo, J., Wang, S., Mao, Y., Wang, G., Wu, G., Wu, Y., Liu, Z. 2024. Supervised learning study on ground classification and state recognition of agricultural robots based on multi-source vibration data fusion. Computers and Electronics in Agriculture 219, 108791.
Höffmann, M., Patel, S., Büskens, C. 2023. Optimal Coverage Path Planning for Agricultural Vehicles with Curvature Constraints. Agriculture 13(11), 2112.
Liu, J., He, L.P., Li, Z., Shi, W. 2020. Energy Efficient Path Planning for Indoor Wheeled Mobile Robots. In: Proceedings of the 2020 Global Reliability and Prognostics and Health Management (PHM-Shanghai), 1–6. Shanghai, China. 13-16 October 2020.
Postmes, J., Sirmacek, B. 2021. A System for Efficient Path Planning and Target Assignment for Robotic Swarms in Agriculture. In: Proceedings of the 11th International Conference on the Internet of Things (IoT '21), 121–128. Enschede, Netherlands. 8-12 November 2021.
Sadhin, A.H., Hashim, S.Z.M., Samma, H., Khamis, N. 2023. YOLO: A Competitive Analysis of Modern Object Detection Algorithms for Road Defects Detection Using Drone Images. Baghdad Science Journal. https://dx.doi.org/10.21123/bsj.2023.9027.
Vahdanjoo, M., Gislum, R., Sørensen, C.A.G. 2023. Operational, Economic, and Environmental Assessment of an Agricultural Robot in Seeding and Weeding Operations. AgriEngineering 5(1), 299–324.
Yin, X., Dong, W., Wang, X., Yu, Y., Yao, D. 2024. Route planning of mobile robot based on improved RRT star and TEB algorithm. Scientific Reports 14, 4513.
Yu, X., Fan, Z., Wan, H., He, Y., Du, J., Li, N., Yuan, Z., Xiao, G. 2019. Positioning, Navigation, and Book Accessing/Returning in an Autonomous Library Robot using Integrated Binocular Vision and QR Code Identification Systems. Sensors 19(4).
Zhou, X., Yan, J., Yan, M., Mao, K., Yang, R., Liu, W. 2023. Path Planning of Rail-Mounted Logistics Robots Based on the Improved Dijkstra Algorithm. Applied Sciences 13(17), 9955.
Zou, T., Angeles, J., Hassani, F. 2018. Dynamic modeling and trajectory tracking control of unmanned tracked vehicles. Robotics and Autonomous Systems 110, 102–111.
Hiremath et al. 2014 Hiremath, S. A., van der Heijden, G. W., van Evert, F. K., Stein, A., & ter Braak, C. J. (2014). Laser range finder models for autonomous navigation of a robot in a maize field. Computers and Electronics in Agriculture, 100, 41-50.
Lu et al. 2014 Lu, D. V., Hershberger, D., & Smart, W. D. (2014). Layered Costmaps for Context-Sensitive Navigation. In 2014 IEEE/RSJ International Conference on Intelligent Robots and Systems, 709-715.
Macenski, S., Martín, F., White, R., & Clavero, J. G. (2020). The Marathon 2: A Navigation System. In 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2718-2725.
Williams, G., Wagener, N., Goldfain, B., Drews, P., Rehg, J. M., & Theodorou, E. A. (2017). Information theoretic MPC for model-based reinforcement learning. In 2017 IEEE International Conference on Robotics and Automation (ICRA), 1714-1721.
Mousazadeh 2013 Mousazadeh, H. (2013). A technical review on navigation systems of agricultural robots. Journal of Agricultural Engineering and Technology, 1(4), 1-22.
Arkin, R. C. (1998). Behavior-Based Robotics. MIT Press.
